> ## Documentation Index
> Fetch the complete documentation index at: https://docs.almond.bot/llms.txt
> Use this file to discover all available pages before exploring further.
# Axol + Jelly
> Axol Jelly setup.
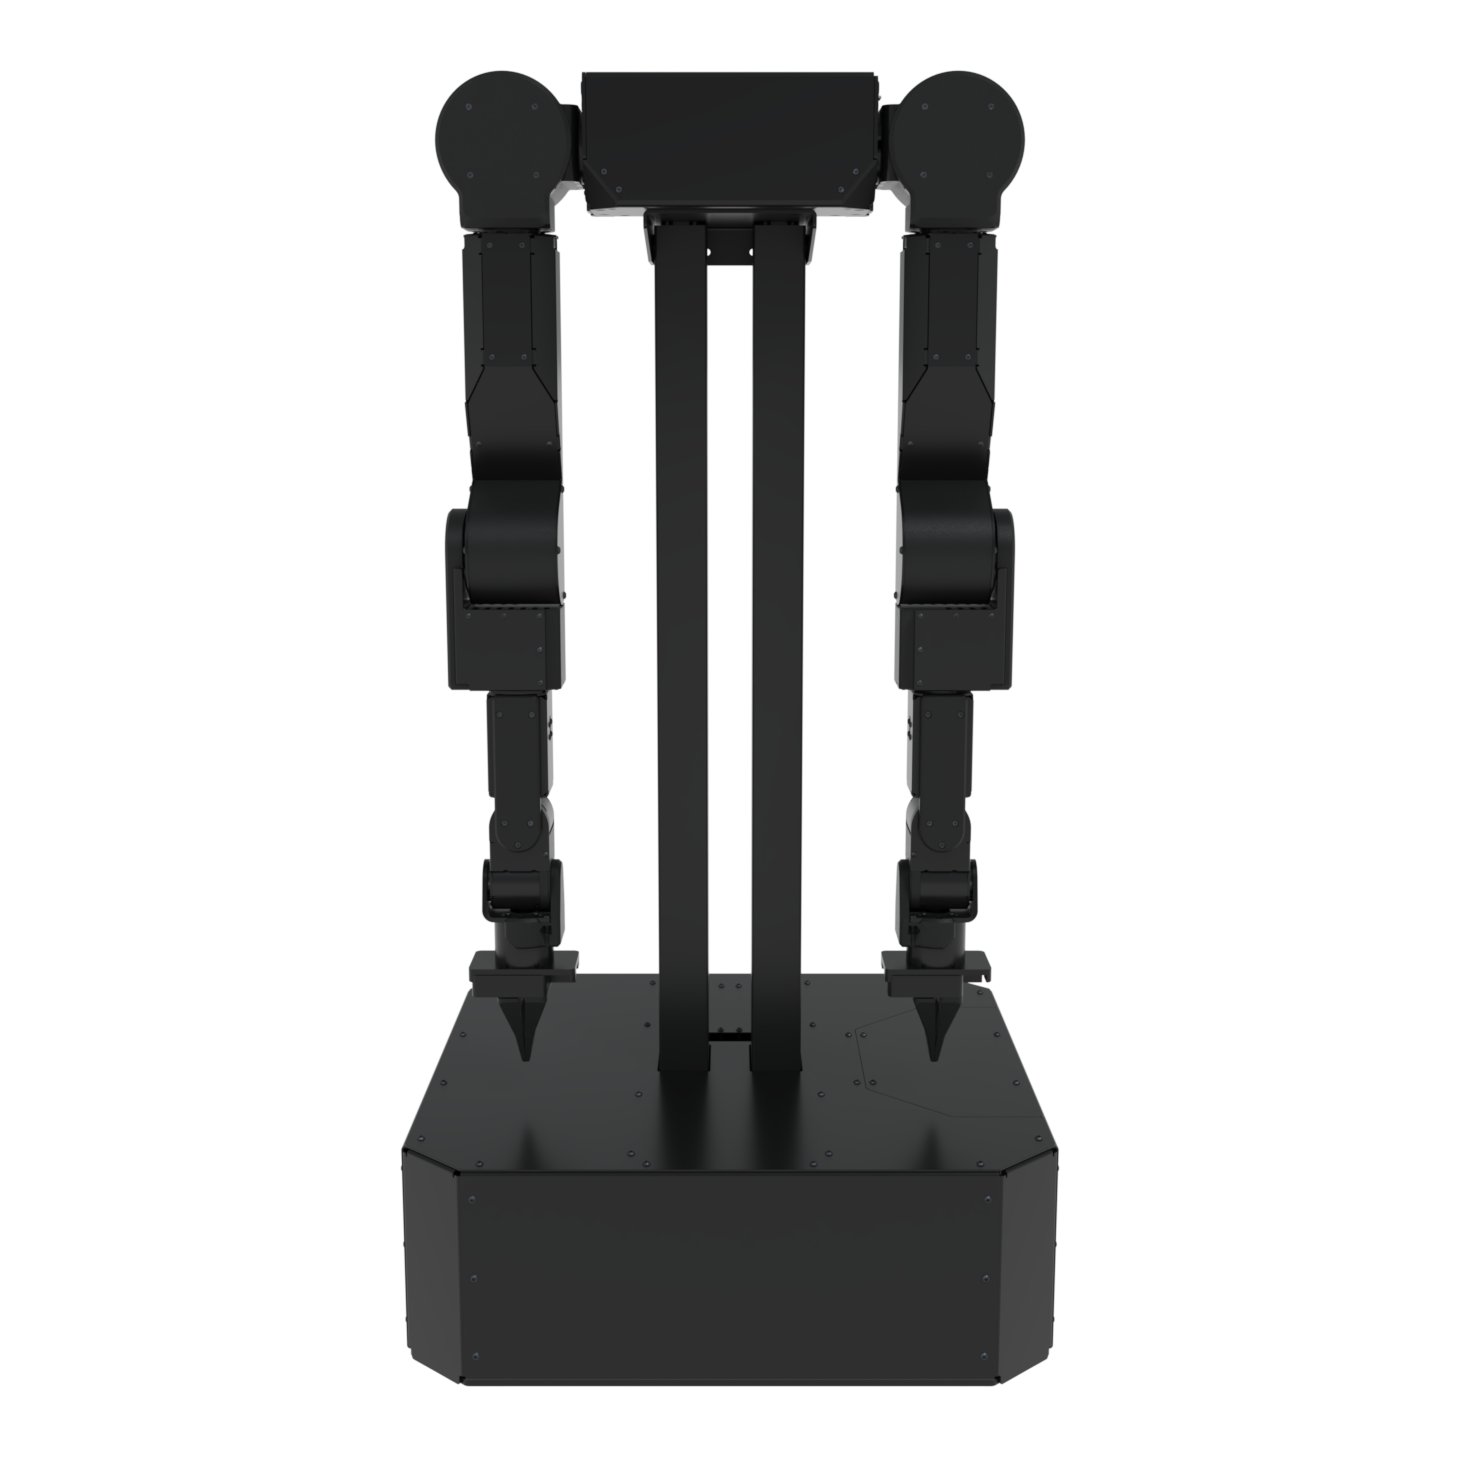 Jelly Mobile is the **powered mobile base**: a holonomic omni-wheel drive, a 610mm telescoping lift, and a 2.4 kWh battery. Once set up, the headset thumbsticks drive it during teleop. See [Jelly in the VR interface guide](/guides/vr-interface#jelly). Specs are on the [Jelly Mobile product page](https://www.almond.bot/jelly-mobile), and base and lift dimensions are in the [outline drawing](https://www.almond.bot/resources/jelly_outline.pdf) (PDF).
### Tools required
You'll need a hex (Allen) key for the M8 bolts that mount Axol, and a Torx driver for the bolts that mount the compute (M6 or M3, depending on which one you have):
| Screw | Driver |
| -------------------- | -------- |
| M8 (Axol) | 6 mm hex |
| M6 (Jetson AGX Orin) | T30 Torx |
| M3 (ZED Box Orin) | T10 Torx |
### Power panel
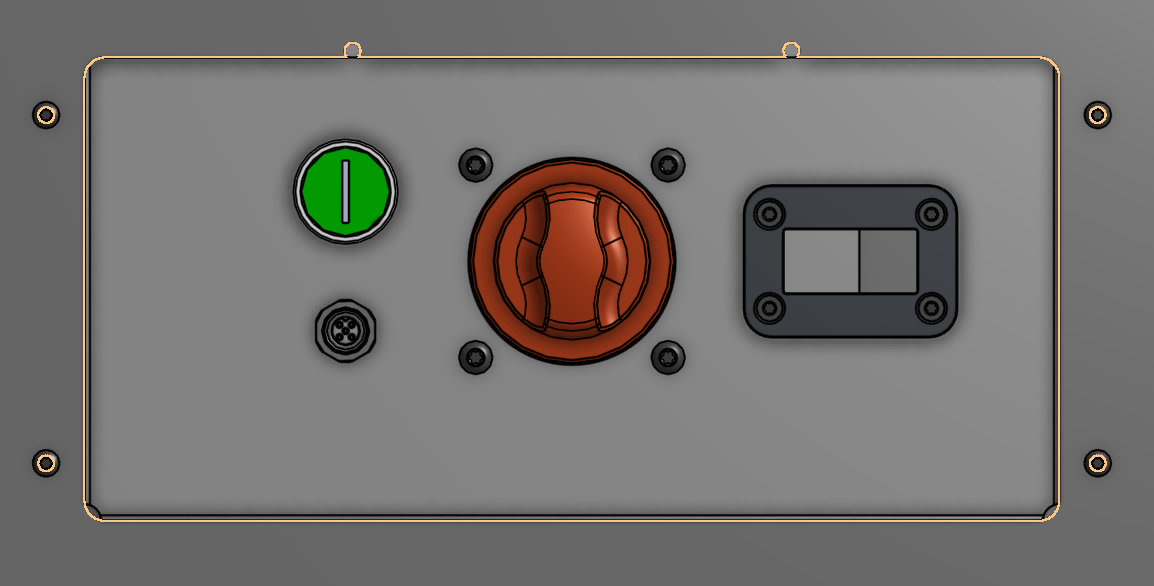 Everything electrical on Jelly goes through the panel on its back:
* **Green on-switch**: starts Jelly once the power switch is on and the E-Stop is disengaged.
* **E-Stop connector** (below the on-switch): plug the E-Stop in here. Keep it somewhere the operator can reach.
* **Red power switch**: the main power switch. Turn it off to fully de-energize the base.
* **Anderson connector**: the charge port. See [Charging Jelly](#charging-jelly).
The E-Stop immediately cuts power to the robot, causing the arms to drop. It does not cut power to the Jetson.
Abruptly shutting down the Jetson can sometimes corrupt the OS. Shut it down from the OS first, then turn the red power switch off.
### Assembling Jelly
Set Jelly on a level floor with room to work around it.
The cable chain that carries Axol's cables up the lift column may ship with its top end loose for transport. If so, fasten the top bracket of the chain to the top plate so the chain follows the lift as it moves.
Install the Compute Kit in the base compartment as described in [Mounting the compute](#mounting-the-compute) below.
Plug the E-Stop into its connector on the [power panel](#power-panel) above and make sure it is disengaged, turn the red power switch on, then press the green on-switch. The compute in the base boots with it.
Run [`axol lift.goto`](/cli/lift-goto). Its default target of **75%** is the robot install height, comfortable for sliding Axol onto the mounting plate. The lift ships homed, so there is no calibration to run first.
Follow [Mounting Axol](#mounting-axol) below: four **M8×12 bolts** with locking washers, threaded in from underneath the plate.
Plug the **XT90** power lead and **USB-C** control cable into the back of Axol. Then fit the cameras with the [Axol Cameras](/hardware-setup/cameras) guide. Their GMSL cables are already connected at the compute end.
Drive the base and lift from the headset thumbsticks during teleop. See [Jelly in the VR interface guide](/guides/vr-interface#jelly).
### Mounting the compute
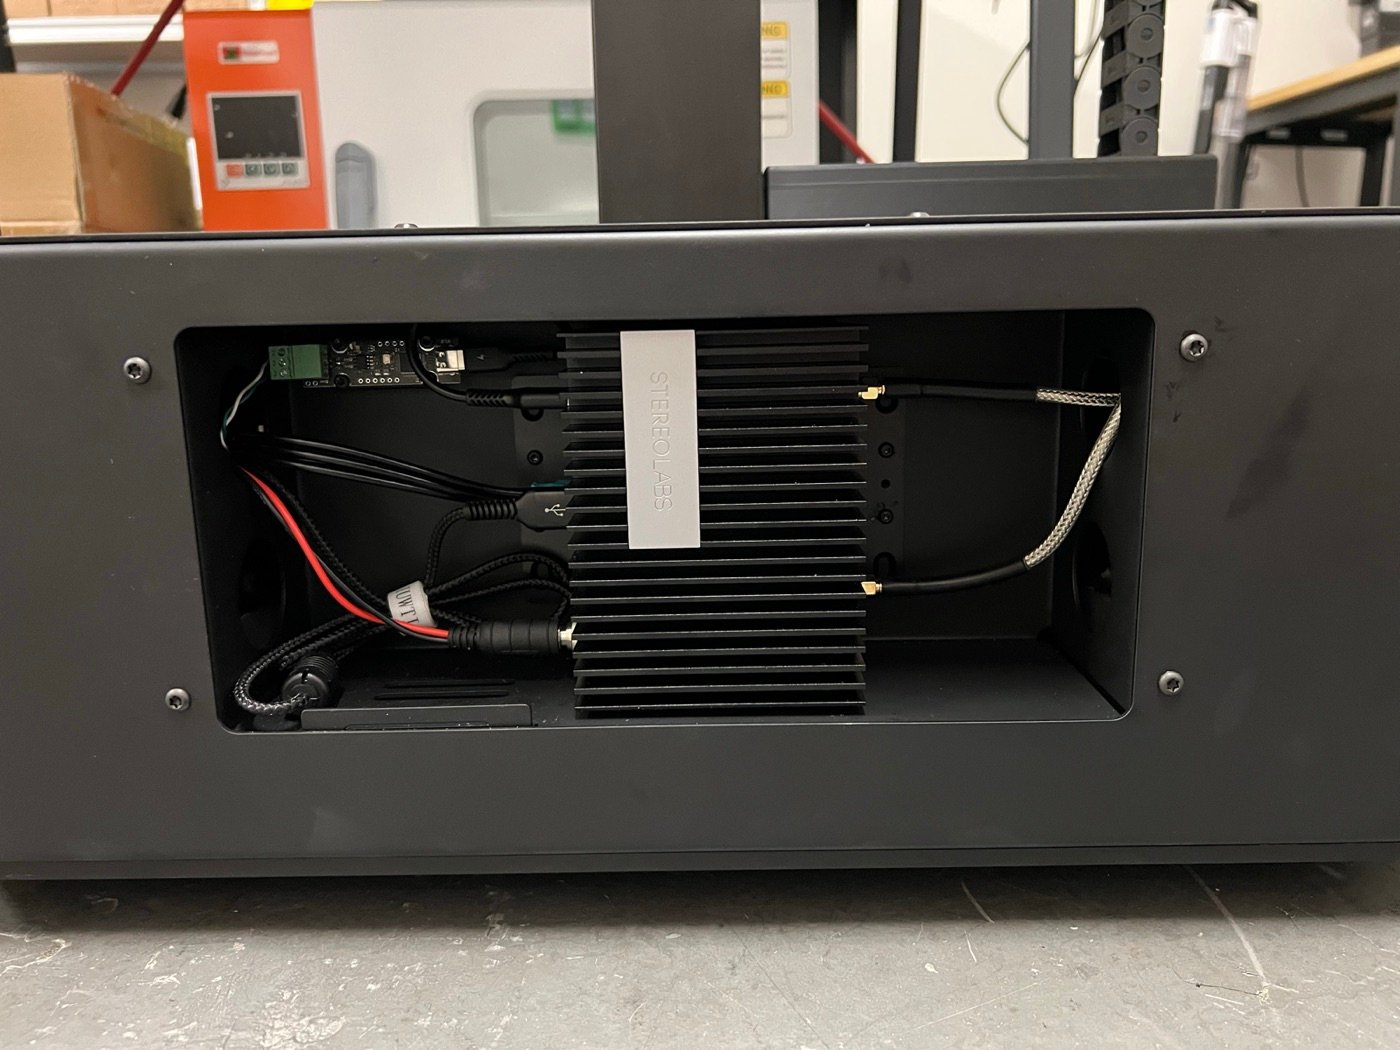 The Compute Kit is **not pre-installed**. It mounts inside the compartment in Jelly's base, which provides a **19V DC power lead** (up to **5A**) from the battery and the **CAN adapters** for the wheels and lift. The compartment also carries the base's **antenna cables** (the braided pair on the right in the photo), which connect to the compute's antenna ports. Every cable the compute needs is already in the compartment: the power lead, the CAN adapters, the antenna cables, Axol's **USB-C** control cable, and the Camera Kit's **GMSL cables**. You only plug them in.
Fasten the compute into the base compartment using the mounting brackets that come with it, heatsink fins facing out so it can breathe. The bolts depend on which compute you have:
* **ZED Box Orin**: 4× **M3×12** Torx bolts (T10).
* **Jetson AGX Orin**: 4× **M6×12** Torx bolts (T30).
Plug the compartment's **19V, 5A** DC power lead into the compute's power input, the wheel and lift **USB-to-CAN** adapters into its USB ports, and the two **antenna cables** onto the compute's antenna connectors.
Plug Axol's USB-C control cable into a USB port on the compute and the GMSL cables into its **GMSL2** inputs.
### Mounting Axol
Axol attaches to its mounting plate with four **M8×12 bolts** and their **locking washers**, threaded in from underneath. See the [mounting holes diagram](https://www.almond.bot/resources/axol_mounting_holes.pdf) for hole positions.
We recommend using **two people** to lift and place it on the mount.
Have the four **M8×12 bolts** and **locking washers** ready, along with a **6 mm hex key**.
With two people, lift Axol and set it on the mount, aligning its mounting holes with the holes in the mounting plate.
From underneath the mounting plate, pass each M8×12 bolt (with its locking washer) up through the plate and into Axol's mounting holes.
Tighten all four bolts with the 6 mm hex key to lock Axol in place.
### Charging Jelly
Jelly runs from a **2.4 kWh** battery good for **4 to 10 hours** depending on how much you drive and lift. It charges through the **Anderson connector** on the power panel, using the charger in the box.
Stop driving, shut the Jetson down from the OS, then turn the red power switch off. The lift holds its position unpowered, so it can stay wherever it is.
Plug the charger into a wall outlet, then into the Anderson connector on the power panel.
Leave it connected until the charger reports full. Unplug the charger before powering Jelly back on.
## Next steps
Mount the Camera Kit's wrist and head cameras and wire them to the compute.
Install Axol on the robot machine and open the web control panel.
Back to the setup guides for every configuration.